


博士生导师
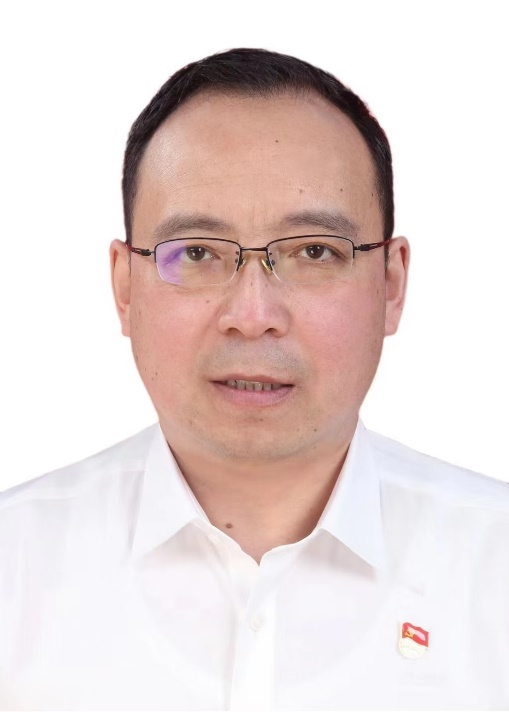

李成松,男,工学博士,西南大学教授、博士生导师。长期从事林果业生产全程机械化关键技术与智能装备、丘陵山地智能农机装备研发等方面的研究工作。主要开展了柑橘精准变量施肥机器人、固态有机肥高效作业机械、智能水肥深施机、烟草分层成熟采收机、林果低损高效收获装备、自主跟随式智能转运机器人等研发工作。主持国家自然科学基金、重庆市技术创新与应用发展专项等国家及省部级科研项目12项;以第一作者或通讯作者发表学术论文50余篇,主编或参编著作9部;获国家专利及软件著作权授权40余项;获省部级科研奖励7项;指导学生参加课外竞赛获全国奖励6项。
林果业生产机械化技术与智能装备研发
丘陵山地农业机器人研发
丘陵山地烟草生产智能装备研发
担任中国农业机械学会丘陵山区农林机械分会副主任委员,中国农业机械学会标准化分会委员,重庆市设施农业创新团队副首席专家,重庆市科学技术协会科学传播专家,重庆市农业机械学会收获机械专委会副主任委员,重庆市农业机械学会团体标准技术委员会副主任委员。国家自然科学基金函评专家。
1. 柑橘高效种植管理作业机械研发与应用(CSTB2022TIAD-LDX0011),重庆市科技局技术创新与应用发展专项面上项目;
2. 固态有机肥高效作业机械研发与应用(cstc2021jscx-gksbX0007),重庆市科技局技术创新与应用发展专项重点项目;
3. 山地柑橘精准变量施肥机器人研发,重庆市人民政府与中国农业科学院科技创新战略合作项目;
4. 烟草分层成熟采收机的研制及应用(HN2023KJ06),中国烟草总公司湖南省公司科技项目;
5. 烟草施肥机及配套施肥技术研究与应用(2023431000240136),湖南省烟草公司郴州市公司科技项目;
6. 加工番茄果秧振动分离机理及振动发生器的研究(51265046),国家自然科学基金项目;
7. 枸杞振动采收机理与机构的研究(51541509),国家自然科学基金项目;
8. 基于耗散效应的南疆红枣分层激励采收能量传递机理研究(52265036),国家自然科学基金项目;
9. 橘园机械化除草关键技术研究与装备开发(SWU019016),西南大学中央高校基本科研业务费项目。
1. Design and evaluation of a multi-sensor fusion navigation system for autonomous orchard weeding robot,Smart Agricultural Technology,2026;
2. Construction and testing of an empirical model for calculating the tumbledrange of dry prickly ash particles on the separation belt,Computers and Electronics in Agriculture,2024;
3. Mechanism of Centrifugal Force Amplitude–Frequency Decoupling Exciters for Fruit Tree Vibration Harvest,Agriculture,2024;
4. Modelling and numerical simulation of a concentrated mass-based branch vibration,Scientia Horticulturae,2024;
5. Design and testing of a Pleurous pulmonarius stick cutting machine,Agriculture,2024;
6. AFC-ResNet18: A Novel Real-Time Image Semantic Segmentation Network for Orchard Scene Understanding,Journal of the ASABE,2024;
7. 基于TRIZ理论的半径可调式林果振动采收激振器设计与试验,农业机械学报,2024;
8. Design and simulation analysis of furrowing and fertilization equipment based on segmented screw mechanism,Cogent Food & Agriculture,2023-12;
9. A novel real-time image semantic segmentation network for orchard scene understanding,American Society of Agricultural and Biological Engineers,2023-11;
10. Potato Planter and Planting Technology: A Review of Recent Developments,Agriculture-Basel,2022-10;
11. Construction of constitutive model and parameter determination of green Sichuan pepper (Zanthoxylum armatum) branches,Biosystems Engineering,2023-03;
12. 基于下桩采摘的干后青花椒脱粒装置研究,中国农机化学报,2023;
13. 双螺旋振动式马铃薯供种装置离散元仿真及优化,中国农机化学报,2023;
14. Potato Planter and Planting Technology: A Review of Recent Developments,Agriculture-Basel,2022-10;
15. Study on the Dynamic Cutting Mechanism of Green Pepper (Zanthoxylum armatum) Branches under Optimal Tool Parameters,Agriculture-Basel,2022-08;
16. Hyperspectral Sensing of Plant Diseases: Principle and Methods,Agronomy,2022;
17. Evaluation of biomechanical properties of jujube branches and analysis of prediction accuracy based on multi-scale artificially simplified model,AIP Advances,2021-04;
18. Microstructure and biomechanical characterisation of jujube branches,Biosystems Engineering,2020-06。
重庆北碚(400716),西南大学工程技术学院
邮箱1453056262@qq.com